Robotic Arm and GripperProduct Brochure
Flexible Gripper for ReMan Manipulators
Soft grasping at the end-effector of a collaborative robot arm
Product Details
Product Overview
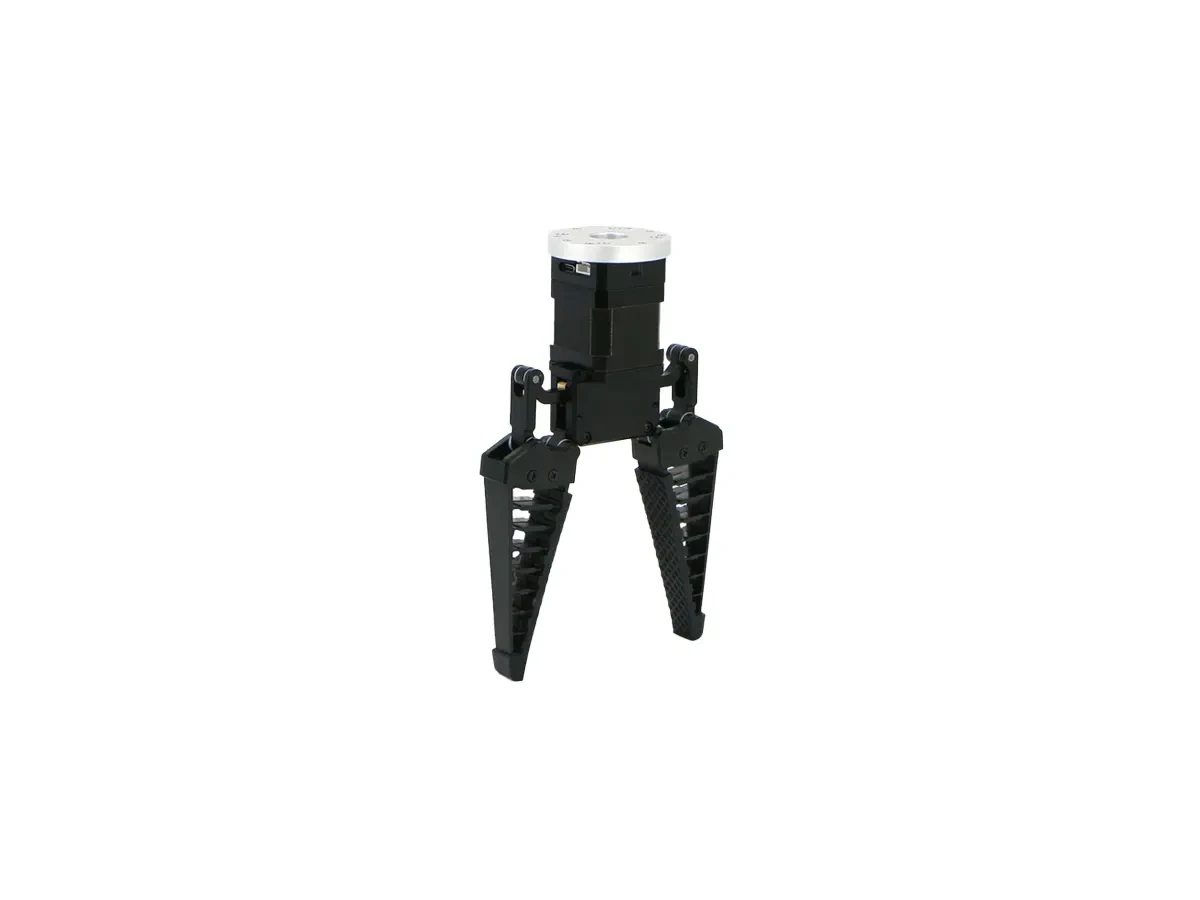
Flexible robotic grippers use deformable fingers instead of rigid jaws, grasping objects by conforming to their shape rather than applying clamping force. Ideal for fragile or irregularly shaped items like fruits and packaged goods.
This gripper is designed for the Robotiq ECO65 series collaborative robots and mounts directly to the end flange. Gripper type and actuation method must be selected based on workpiece dimensions and cycle time; providing samples or drawings during selection will accelerate compatibility matching.
Other models in the same series
Key Features
- Flexible gripper fingers adapt to irregular, fragile workpieces without scratching surfaces during grasping.
- Compatible with RAILMAN ECO65 series collaborative robots; direct mounting to the end-effector flange
- Choose pneumatic or electric version based on workpiece and cycle time.
Typical Applications
- Pick and Sort of Fragile Workpieces
- Flexible loading of mixed-line multi-specification workpieces
- Collaborative Robot End-Effector Training Demo
Technical Specifications (6Item
- Adapt to robotic arms
- Realman ECO65 Series Collaborative Robots
- Claw form
- Flexible bionic finger, multi-finger structure
- Crawling Method
- Confirm pneumatic/electric version based on selection.
- Installation Method
- Direct mounting of the robot arm's end flange
- Typical Workpiece
- Irregular, fragile, mixed-specification workpieces on multi-line
- Selection Criteria
- Gripper type, finger length, and drive method are determined by arm model and workpiece specifications. Refer to the selection sheet for detailed specifications.