Robotic Arm and GripperProduct Brochure
Flexible Biomimetic Robotic Gripper
Available in multiple sizes with pneumatic or electric options
Product Details
Product Overview
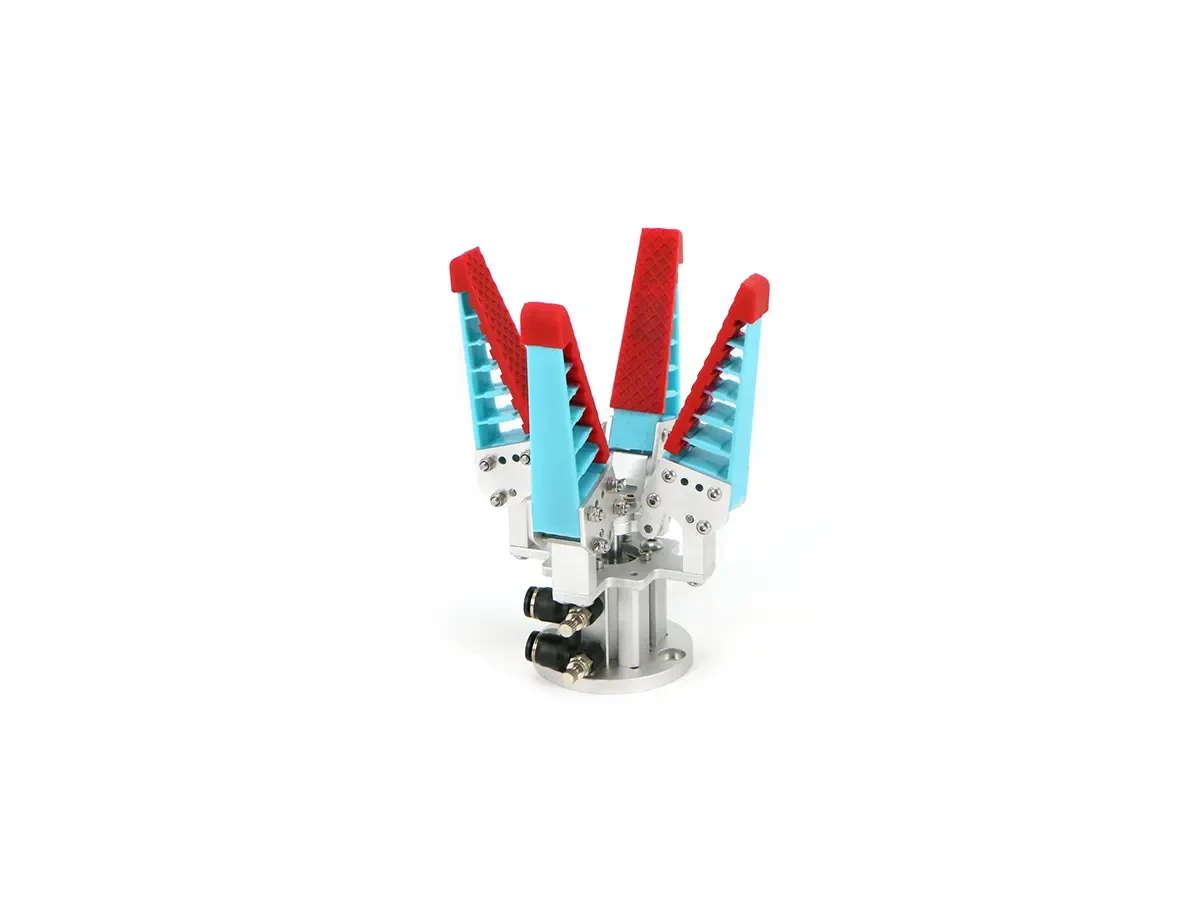
Flexible biomimetic robotic grippers use deformable fingers to conform to workpiece contours, ensuring more uniform grip distribution. Ideal for irregular shapes or delicate surfaces, they are a common end-effector solution for collaborative robots.
The gripper is available in multiple configurations based on type and actuation: pneumatic models for high-frequency grasping, electric versions with simple wiring, and micro-servo options for compact desktop robotic arms. Select the specific grip size and weight capacity based on your workpiece.
Other models in the same series
Key Features
- Two-finger, three-finger, four-finger, and cross-four-finger configurations; select based on workpiece shape.
- Pneumatic version operating pressure: 0.2-0.6 MPa; Electric version power supply: DC12-24V
- Grasps workpieces with dimensions from 10 to 120 mm and weights ranging from 0.6 to 1.5 kg.
Typical Applications
- Pick fragile and irregular workpieces
- Collaborative Robot End-Effector Selection
- Flexible Grasping for Scientific Research and Experiments
Technical Specifications (8Item
- Structural Form
- 2-finger / 3-finger / 4-finger / Cross-4-finger pneumatic grippers; Micro servo electric grippers
- Pneumatic Version Dimensions
- 63×63×158mm minimum (by finger type)
- Pneumatic Version Weight
- 240g / 300g / 350g (by finger type)
- Capture Size
- 10-120mm (Pneumatic); 15-90mm (Servo)
- Grab Weight
- 0.6kg / 1kg / 1.5kg (pneumatic); 0.5-1.2kg (servo)
- Pneumatic working pressure
- 0.2-0.6MPa
- Electric power supply
- DC12-24V
- Servo Model Power Supply
- 5V