Underactuated Self-Balancing / Smart Car KitProduct Brochure
Obstacle-Avoidance Line-Tracking Robot Car
L150 / L150 PRO Dual-Master Edition
Product Details
Product Overview
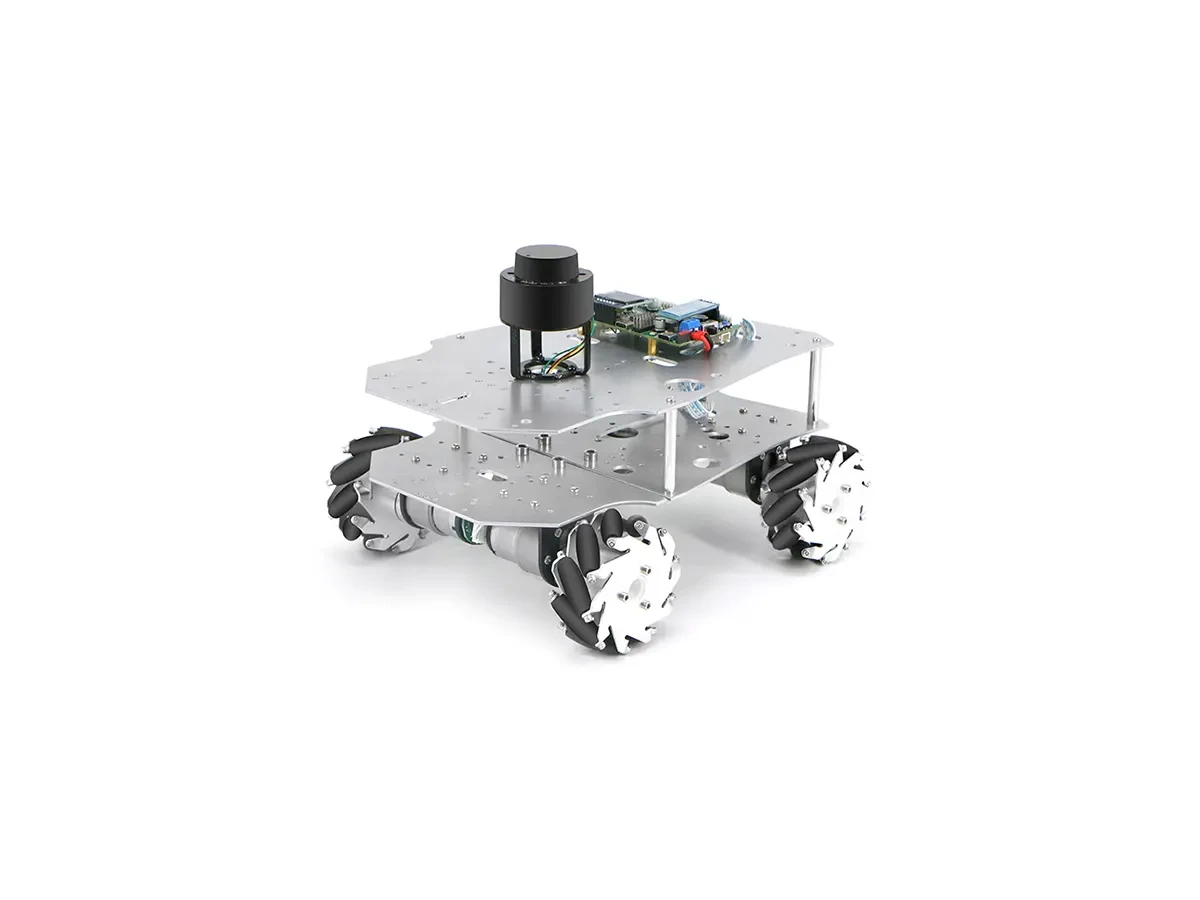
The difference between L150 and L150 PRO lies in the motherboard: C10B supports two-wheel tracking, while C30D is a four-wheel master controller capable of driving Mecanum wheels, omnidirectional wheels, and other configurations, with an onboard MPU6050.
The two main control boards have dimensions similar to the Raspberry Pi. They support one-click serial downloads and SWD debugging, and can connect to external LD14 or N10P LiDARs for obstacle avoidance and radar tracking experiments.
Other models in the same series
Key Features
- L150 with C10B main controller, L150 PRO with C30D 4WD controller; supports Mecanum and omnidirectional wheels.
- The mainboard supports one-click serial download and SWD debugging, with a reserved interface for the MPU6050 module.
- Choose LD14 or N10P LiDAR for line-tracking and obstacle-avoidance experiments.
Typical Applications
- Line Tracking and Obstacle Avoidance Beginner Experiment
- LiDAR Data Processing Tutorial
- STM32 Embedded Control Course Design
Technical Specifications (10Item
- Version & Controller
- L150 (C10B, STM32F103RCT6) / L150 PRO (C30D, STM32F407VET6)
- Driven Encoder
- 2 / 4
- Onboard IMU
- C10B: None (MPU6050 interface reserved); C30D: Onboard MPU6050
- LiDAR
- LD14 / N10P (Optional)
- Control Mode
- App (joystick, gravity sensor, buttons), PS2 controller
- Mainboard dimensions
- 85.5×57.5mm
- Mainboard Weight
- 36g
- Power Supply
- Independent 5V/5A ×1, 3.3V and multiple 5V, parallel battery output ×1
- Download & Debug
- Supports one-click serial download; SWD interface reserved.
- Motor Enable
- 2-channel enable switch