
Teleoperated Robotic Arm for Embodied AI Research
D1-T Teleoperated Robotic Arm
The Unitree D1-T is a teleoperated robotic arm designed for embodied AI research and data collection. It features ultra-precise force-controlled digital servos with position, speed, and force control capabilities. Constructed from aluminum alloy, the arm weighs only 2.37kg when its length is 670mm. It comes standard with six joints and a gripper, supporting integration with external devices such as cameras and mobile robot chassis.
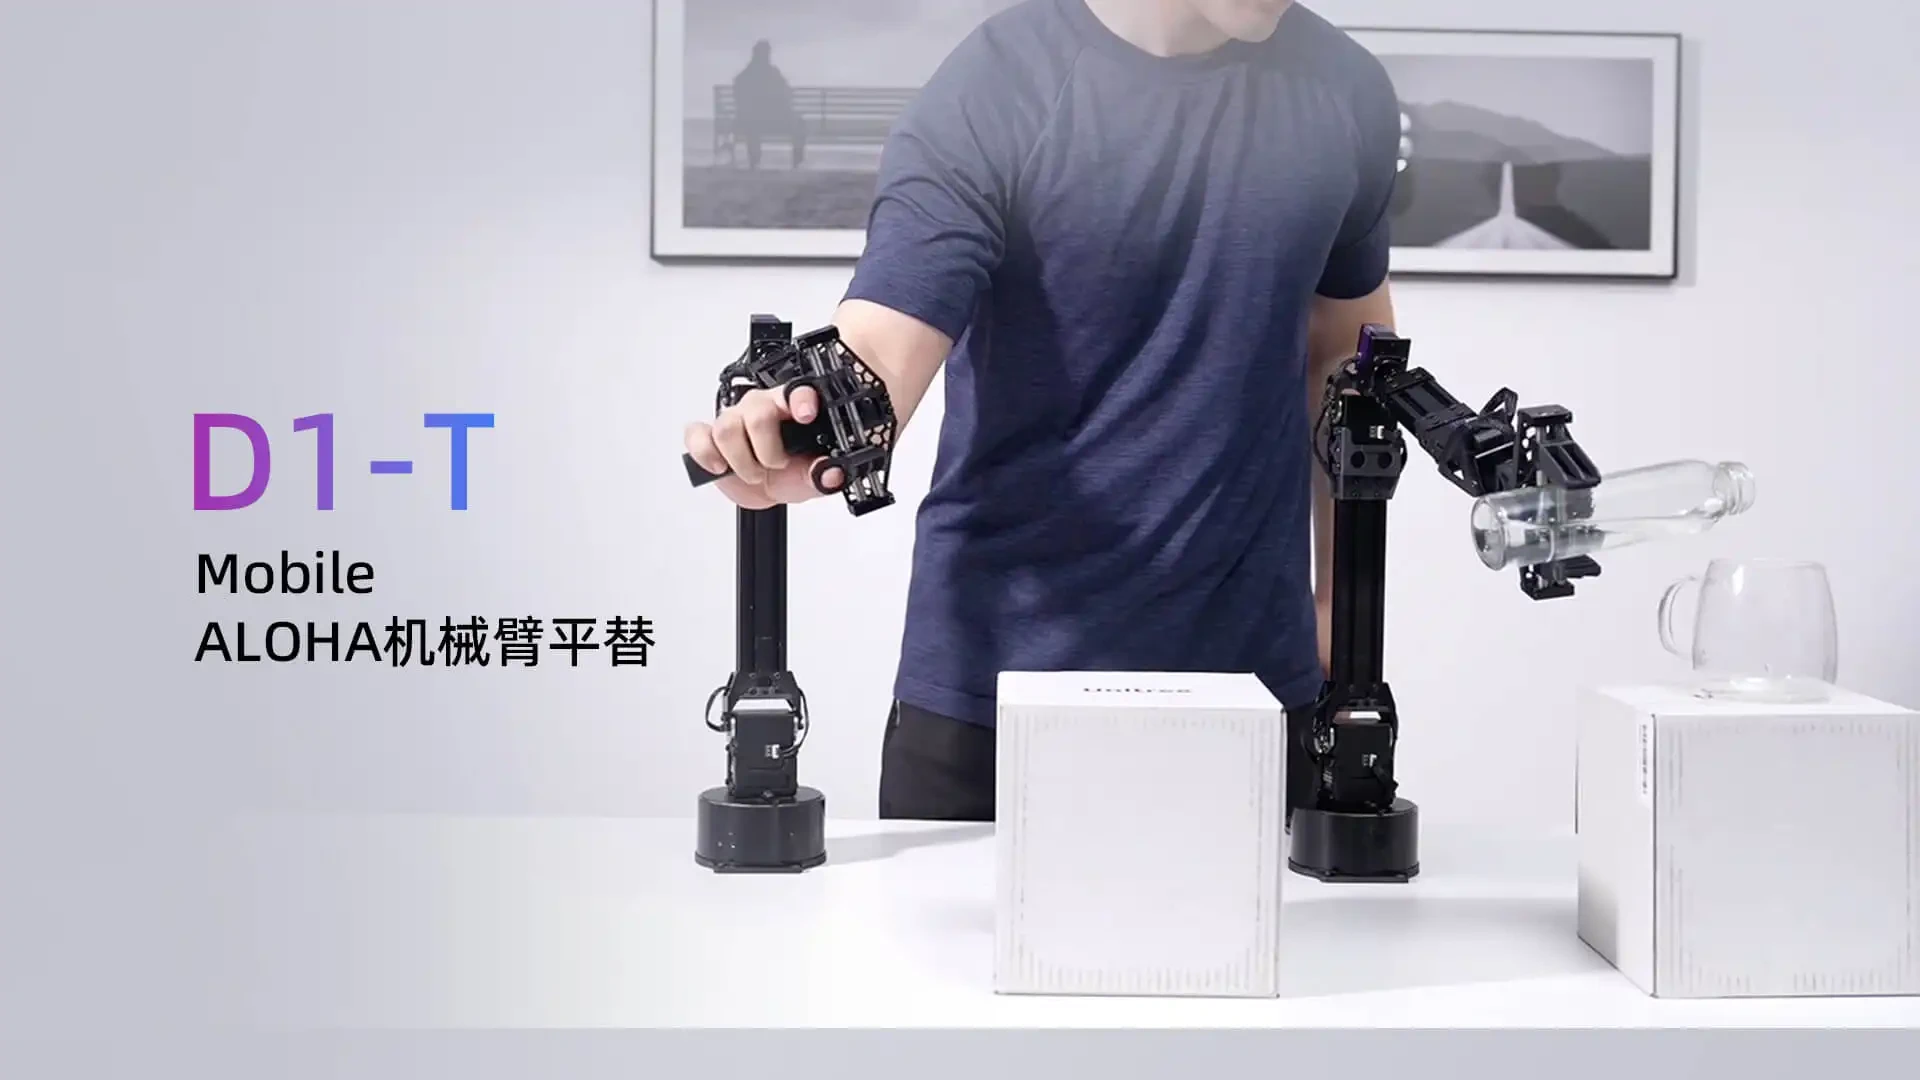
Specifications
Technical Specifications
Weight
About 2.37kg
Degrees of Freedom
6-DOF + 1 Jaw
Load Capacity
500g
Maximum wingspan
550mm (without claw) / 670mm (with claw)
Power Requirements
2 4V 2.5A (Max 5A)
API
DC5.5-2.1 (Power) + RJ45 (Communication) + Type-C (Serial Debugging)
Motor Type
Bus Servo
Power
60W
Features
Features
Ultra-precise bus digital force-controlled servo: Supports position, speed, and torque control for diverse application development and learning tasks.
Ultra-lightweight mechanical arm body: Crafted from aluminum alloy, the arm weighs only 2.37kg at a length of 67mm.
Ultra-high control freedom: True 6-axis robotic arm with six joints and a gripper for enhanced flexibility and range of motion in spatial tasks.
Highly flexible hardware integration: The robotic arm supports connection to external devices such as cameras and mobile robot chassis, enabling adaptation to diverse application scenarios.
Embodied AI Assistant for Data Collection: Offers dual-arm (Standard) and quad-arm (Full) AI teleoperation kits to unlock potential in data collection and continuous learning.
Applications
Use Cases
Embodied AI Research
Data Collection
Educational Training
Teleoperation
Algorithm Development
YesD1-T Teleoperated Robotic ArmInterested?
Contact us for product quotes and technical solutions
Purchase Intent
Submit your requirements and contact details. A sales consultant will confirm pricing, stock availability, and delivery options with you. Product prices are subject to quotation.