
Enterprise-grade quadruped robots
AlienGo Robot Dog
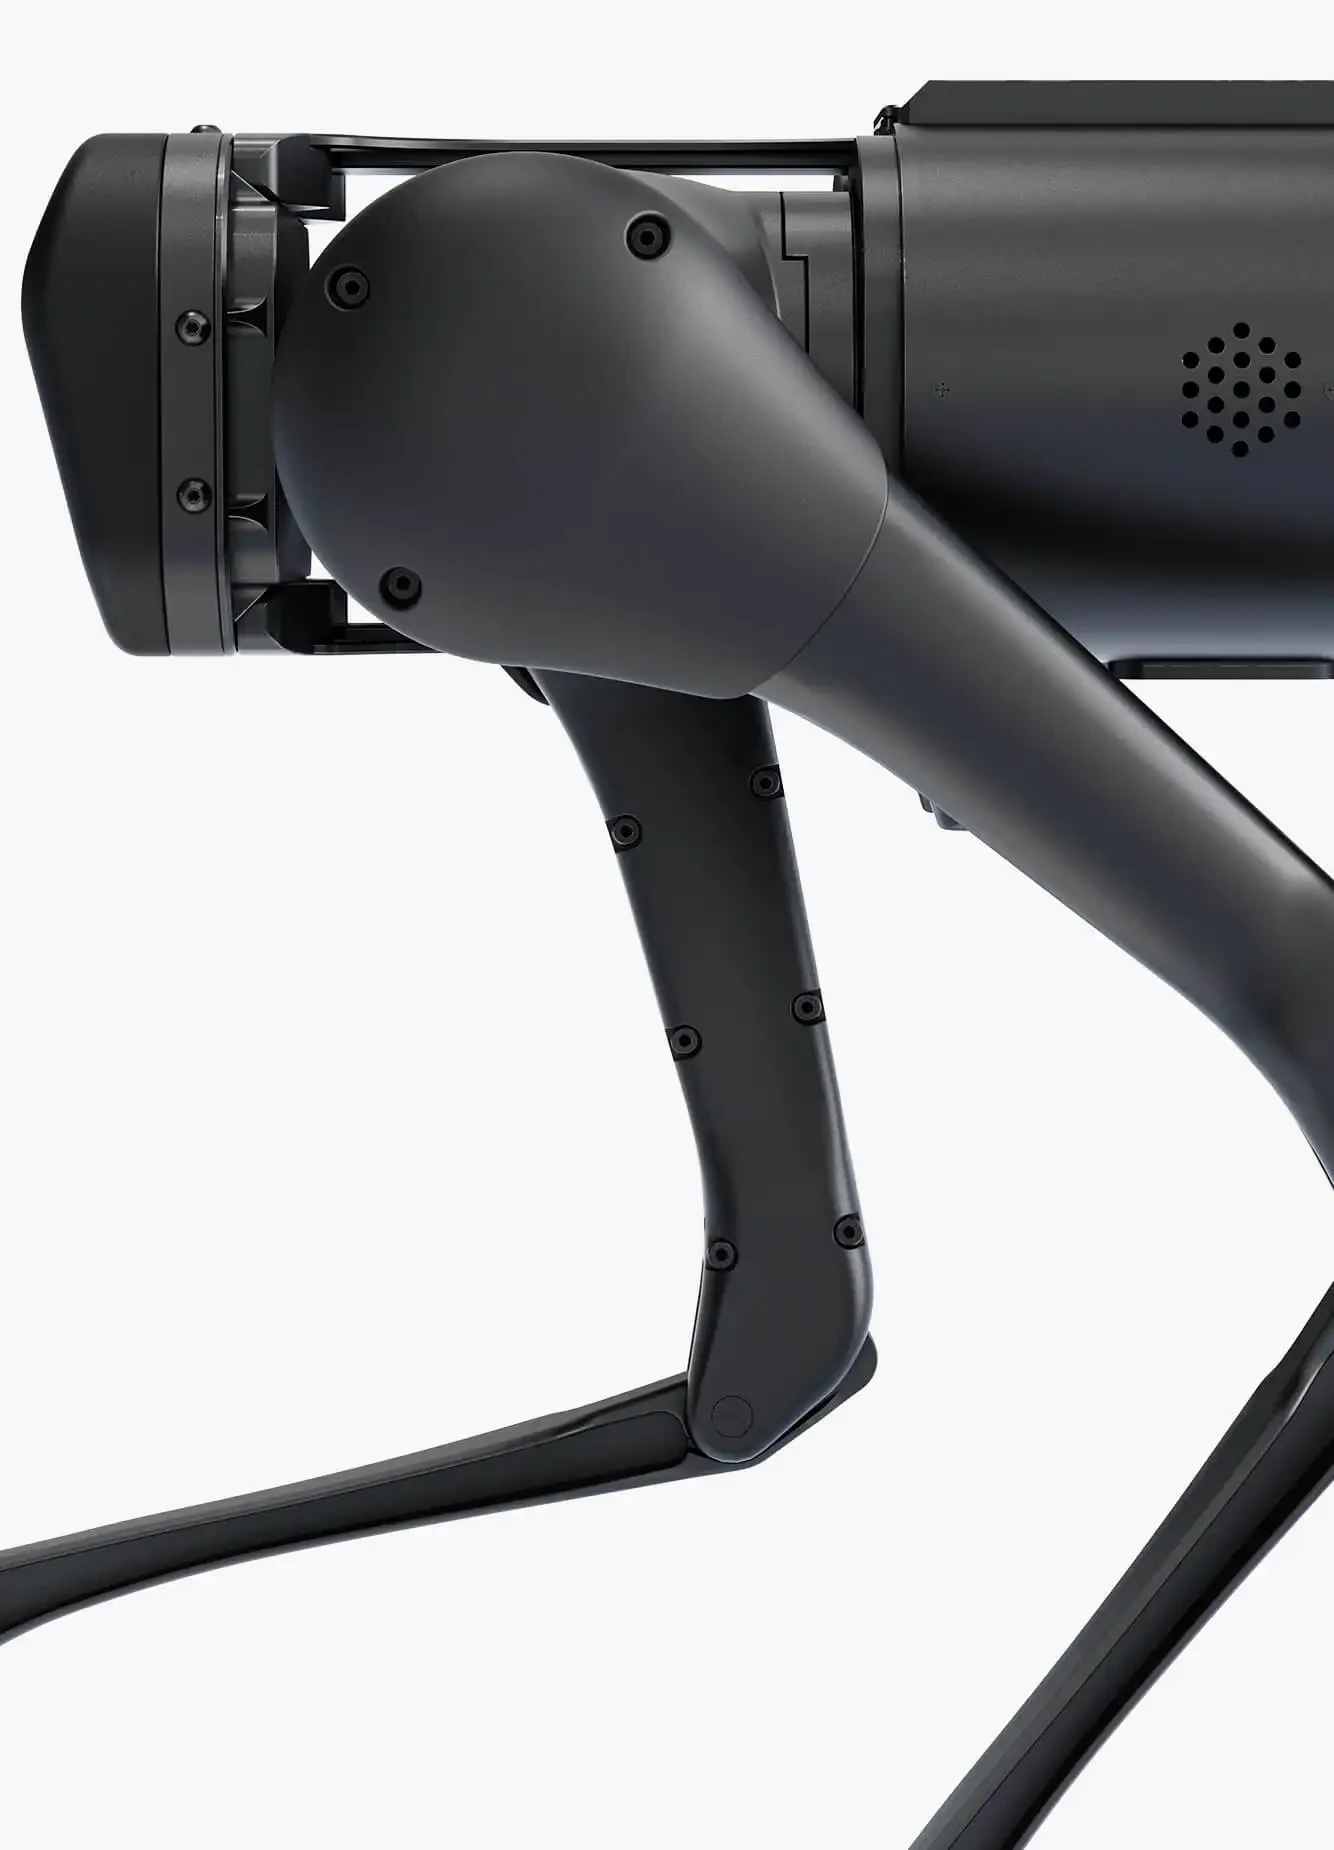
Unitree AlienGo is a professional-grade quadruped robot designed for industrial applications. Equipped with a multi-eye depth perception vision system and 12 high-performance servo motors, it achieves a maximum walking speed of over 1.5m/s, offers a battery life of 2.5-4.6 hours, and supports a payload capacity of up to 13kg. Featuring force control technology for joint composite control, the AlienGo ensures stable operation on rugged terrain such as rocky paths and grassy surfaces.
Specifications
Technical Specifications
Total weight (without battery)
21.5kg ±1 kg
Height, Width, Depth (Standing)
0.65*0.31*0.6m
Dimensions (Folded for Transport)
0.60*0.31*0.15m
Load Capacity
13kg
Maximum walking speed
>1.5 m/s
Climbing Angle
≤25°
Battery Life
2.5-4.6h
Battery Capacity
1260 mAh
Total Degrees of Freedom (Motor Count)
12
Perception capabilities
Depth Camera (2 units), Visual Odometry Camera (1 units), LiDAR (optional)
External Interface
Ethernet x2, USB3.0x2, USB2.0x1, 485 Serial x1
Number of foot force sensors
4
Motion Control
Ubuntu
Environmental Perception
Ubuntu-ROS
Chassis Output Power
5V, 12V, 19V, BAT(24V~30V)
Features
Features
Multi-Depth Perception Visual System: Depth Camera 2 array (global shutter, wide field of view, minimum sensing depth ~0.1m, 1280x720 depth resolution); Visual Odometry Camera 1 array (V-SLAM loop closure error < 1%, latency < 6ms)
Superior Motion Performance: 12 high-performance servo motors enable running, backward running, lateral movement, spinning in place, crawling, somersaulting, jumping, obstacle crossing, obstacle avoidance, and self-righting after falling.
Stable performance: Quickly adjusts attitude to maintain stable operation even under external disturbances.
Excellent Openness: The software control interface (high-level and low-level) supports C/C++ and ROS, enabling reading of various sensor data and control of individual motors or single-leg movements.
Force control for joint composite actuation: Enables full control of 3-axis posture and position, offering exceptional adaptability across diverse terrains. It ensures stable operation on rugged gravel paths and grassy surfaces.
Rich external interfaces: The developer version includes an onboard PC with open APIs, supporting modules such as vision cameras, LiDAR, robotic arms, and GPS systems.
Applications
Use Cases
Industry Security
Inspection Exploration
Education & Research
Complex Terrain Transport
Algorithm Development
YesAlienGo Robot DogInterested?
Contact us for product quotes and technical solutions
Purchase Intent
Submit your requirements and contact details. A sales consultant will confirm pricing, stock availability, and delivery options with you. Product prices are subject to quotation.